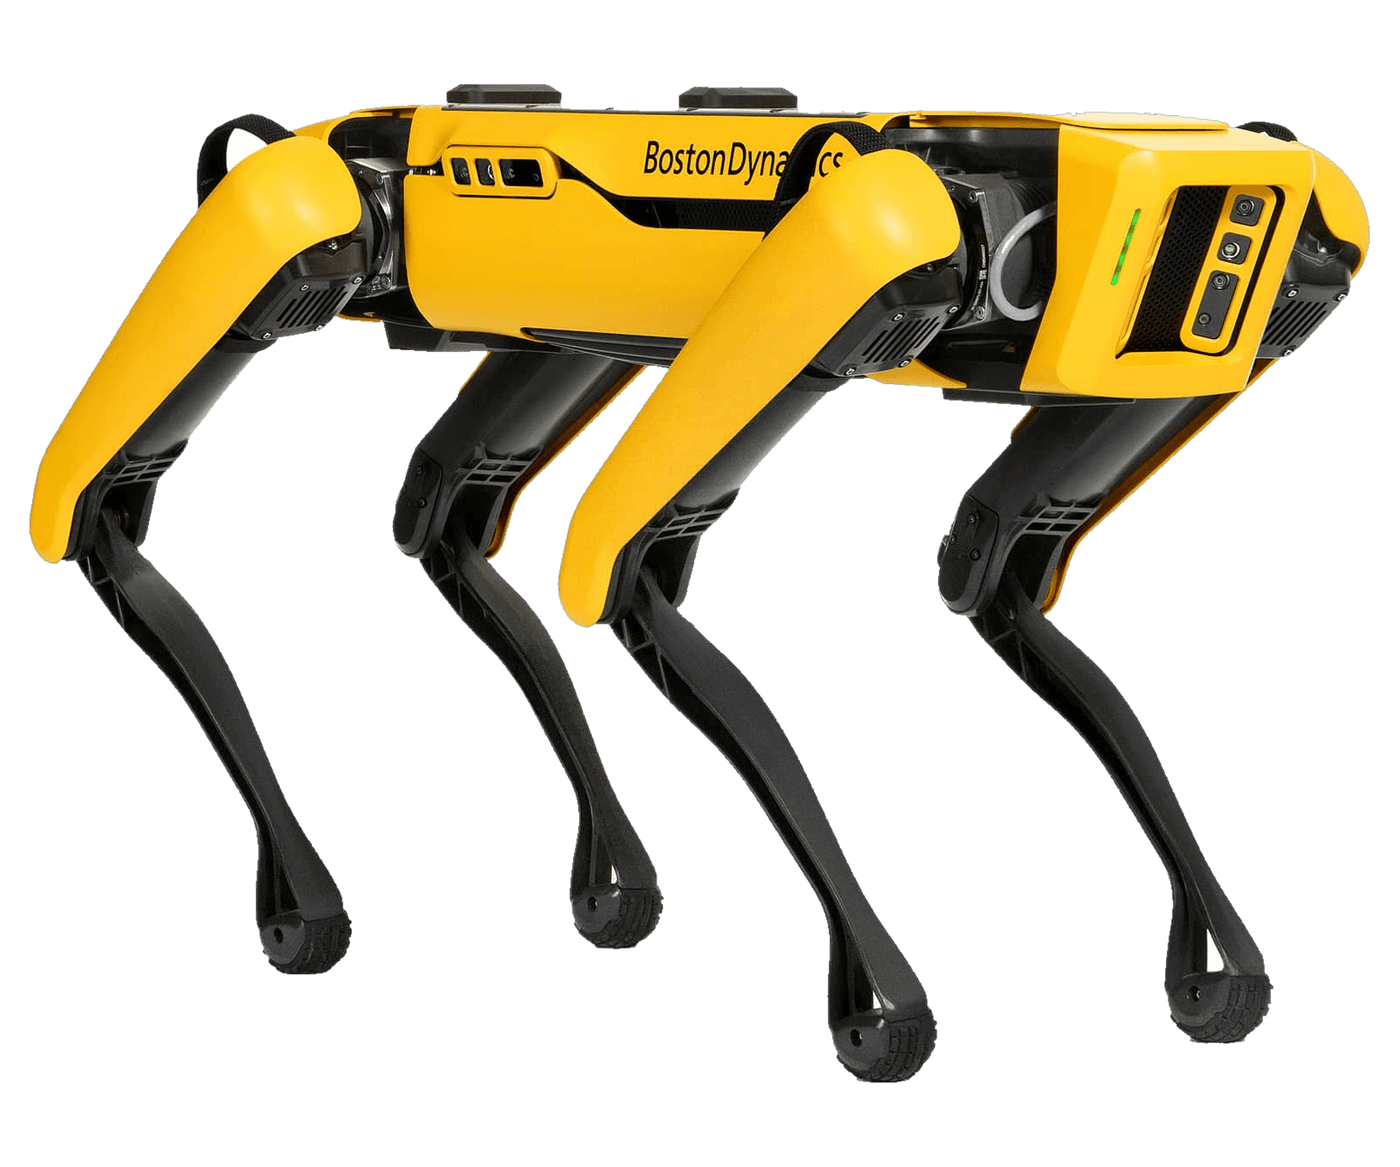
| Platform |
|---|
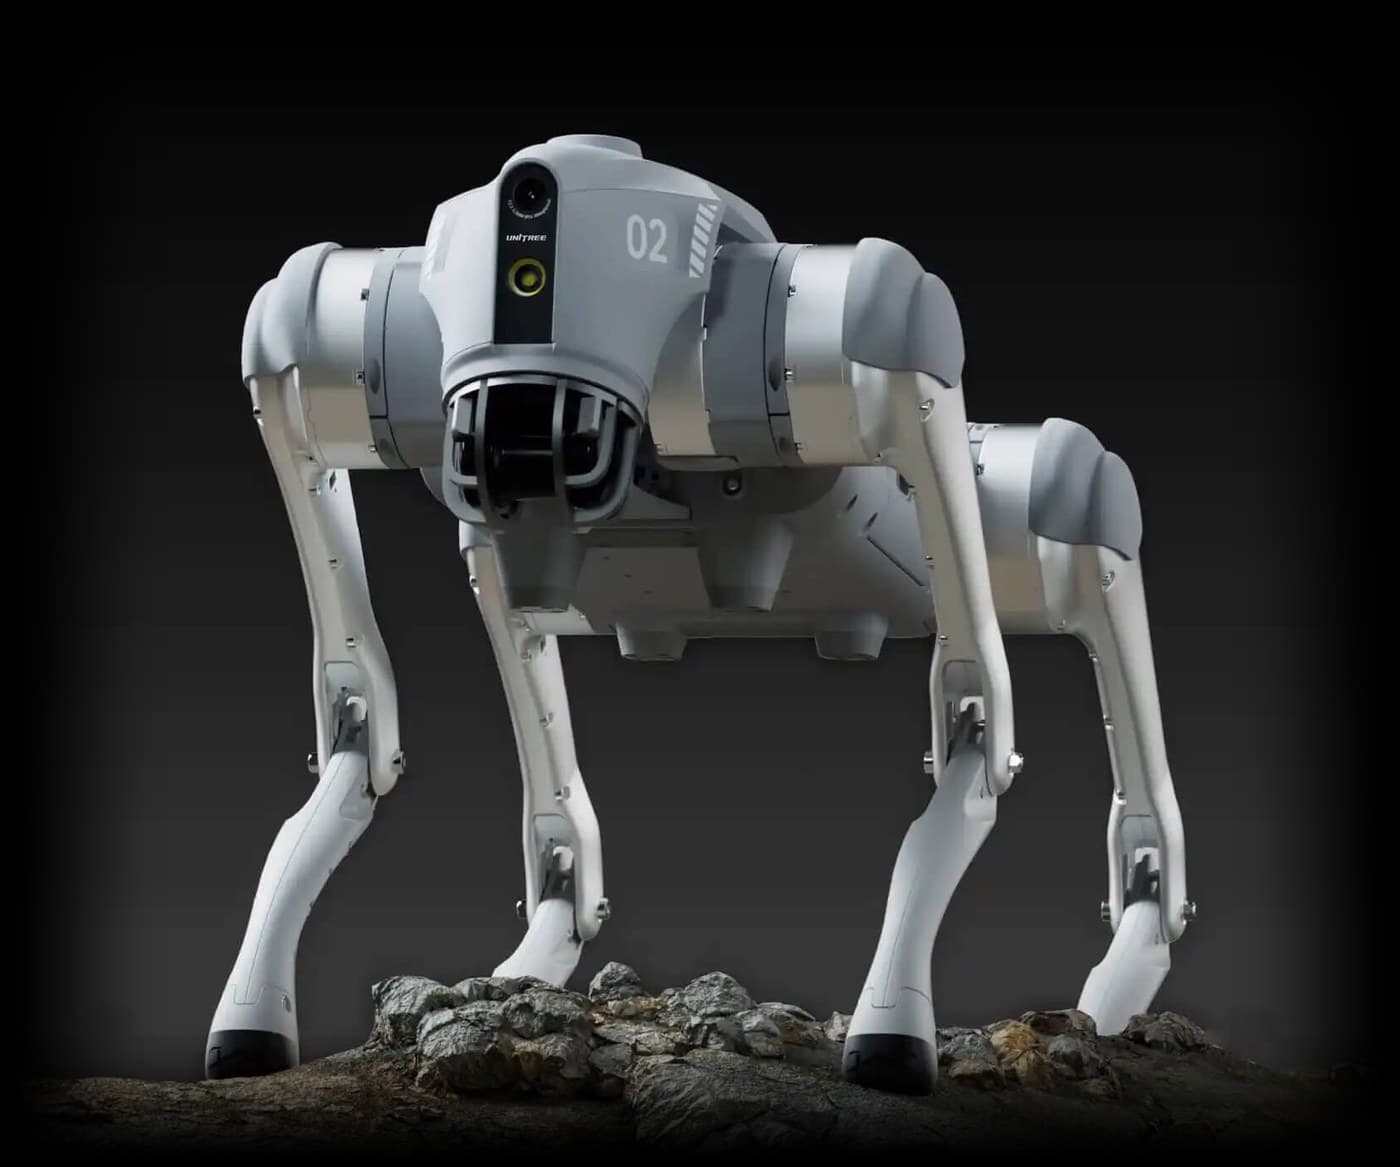
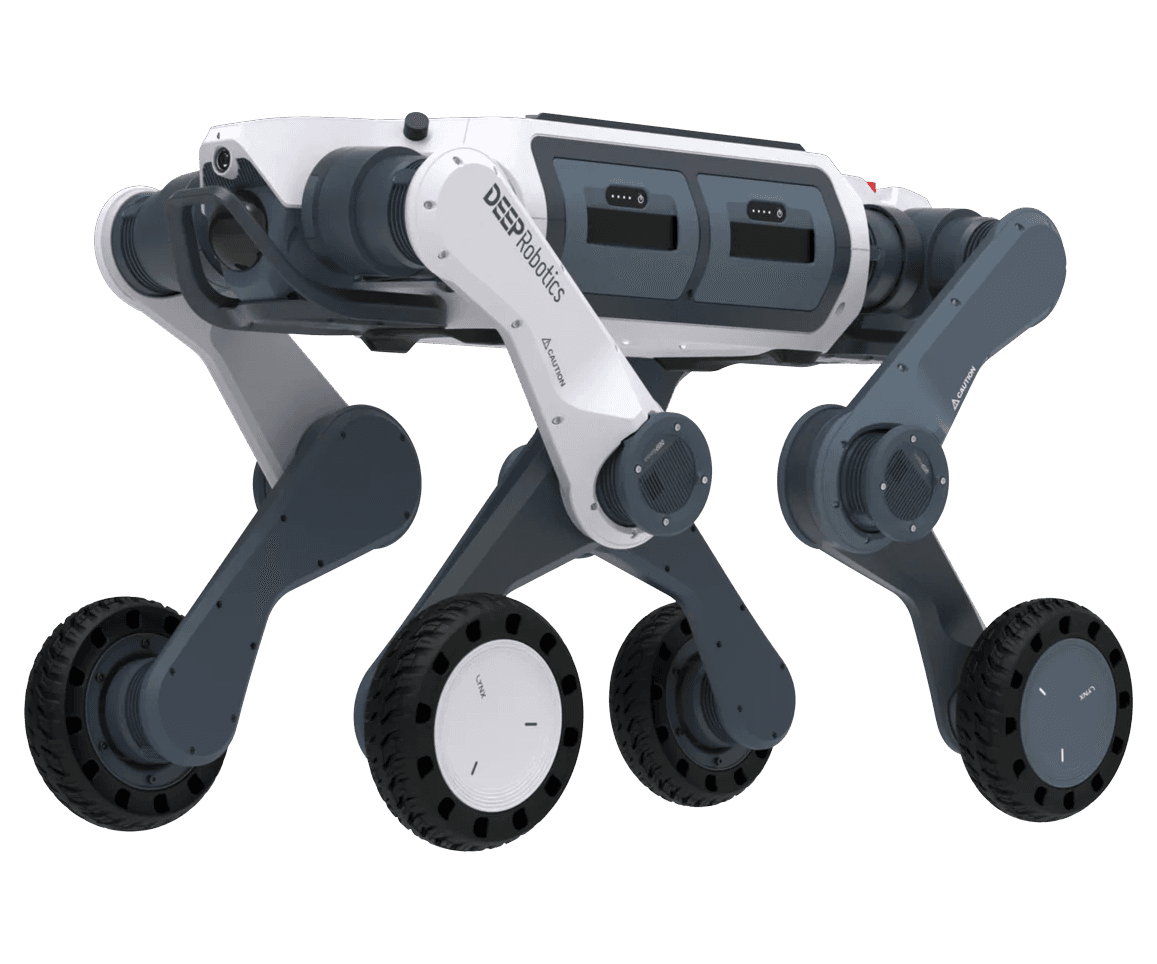
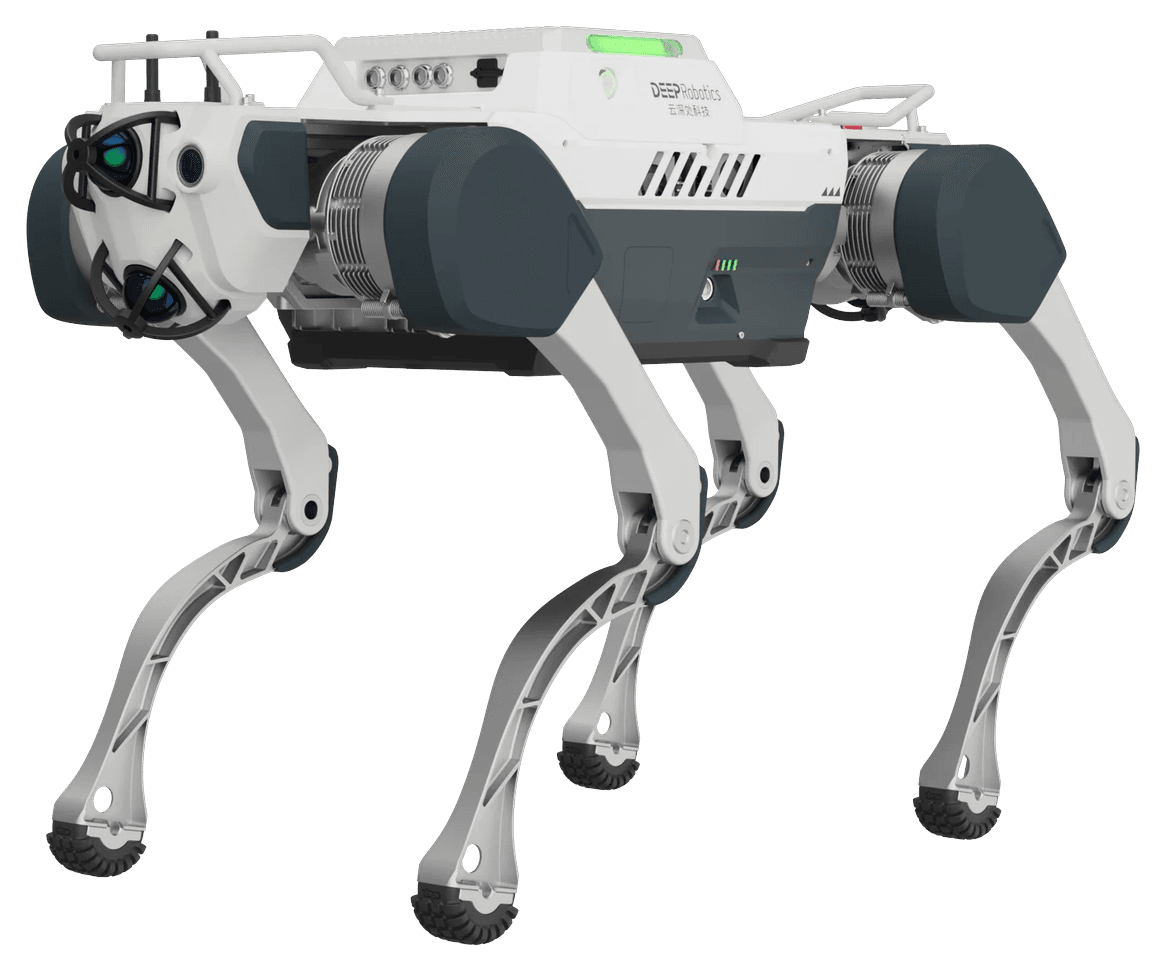
| Form factor | Legged quadruped | Wheel-leg hybrid quadruped | Legged industrial quadruped | Legged quadruped |
|---|
| Weight | ≈15 kg with battery | 35 kg with battery | 56 kg with battery (59 kg Pro) | 33.8 kg with battery (5.2 kg of it battery) |
|---|
| Standing size | 70 × 31 × 40 cm standing; 76 × 31 × 20 cm crouched | 82 × 43 × 57 cm standing | 100 × 69.5 × 47 cm standing (100 × 71.5 × 47 cm Pro) | 110 × 50 × 61 cm standing; 52–70 cm walking height |
|---|
| Rated payload | ≈8 kg continuous | 15 kg rated | ≥20 kg | 14 kg maximum |
|---|
| Maximum load | 12 kg (EDU) | 50 kg | Not published alongside the rated payload | Not published beyond the 14 kg payload |
|---|
| Mobility |
|---|
| Speed | 3.7 m/s normal; 5 m/s maximum | 2 m/s operating; 5 m/s lab-tested, capped at 3 m/s in user mode | 1.2 m/s nominal; ≥4 m/s maximum (4.95 m/s lab-tested) | 1.6 m/s |
|---|
| Max slope | 40° | 45° lab-tested; varies with surface | ≤45° | ±30° |
|---|
| Stairs | ≈16 cm step height | 25 cm continuous stair height | 20 cm continuous step height; climbs stairs at ±45° | 30 cm maximum step height |
|---|
| Single-step obstacle | ≈16 cm | 80 cm single step | ≥20 cm | 30 cm |
|---|
| Power & endurance |
|---|
| Battery | 15,000 mAh (EDU); 8,000 mAh standard; 28–33.6 V | Hot-swappable 72 V, 9 Ah | Quick-swap 72 V, 22.4 Ah | 564 Wh, swappable |
|---|
| Runtime per charge | 2–4 h on the EDU pack; 1–2 h on the standard pack | 3 h unloaded; 2.5 h with 15 kg | 2.5–4 h — 25 % longer than the previous generation | 90 min average; 180 min on standby |
|---|
| Range per charge | Not published by Unitree | 15 km unloaded; 12 km loaded | ≥10 km | Not published by Boston Dynamics |
|---|
| Charging time | Not published by Unitree | 1.5 h per battery | Not published; batteries swap in the field | 60 min |
|---|
| Autonomous charging | No autonomous dock as standard | Self-charging optional | Autonomous charging dock optional | Spot Dock — returns and self-charges between missions |
|---|
| Perception & compute |
|---|
| LiDAR | 4D LiDAR L2, 360° × 96°, minimum range 0.05 m; Livox Mid-360 optional | 2 × 96-line, 360° × 90°, ~860,000 pts/s | Fused LiDAR with depth and infrared imaging (4 × 3D LiDAR on the Pro) | Not fitted as standard; available as a payload |
|---|
| Cameras & lighting | 1 × HD wide-angle (2 MP) with front lamp; no thermal | 2 × wide-angle; front and rear bidirectional lighting | Wide-angle RGB; thermal and PTZ payloads optional | 360° stereo vision to 4 m; Spot CAM+IR adds thermal |
|---|
| Onboard compute | 8-core CPU; optional NVIDIA Jetson Orin (40–100 TOPS) | 3 × dual octa-core 64-bit industrial processors (16 GB + 128 GB) | Industrial onboard compute, not itemised; RTK positioning optional | Onboard compute; payload processing via the I/O module |
|---|
| Autonomy | Obstacle avoidance and visual following; full autonomy needs the optional compute module | SLAM mapping, autonomous navigation, omnidirectional obstacle avoidance, point-cloud surround view | Autonomous navigation in darkness, glare, flicker, or no light at all | Autowalk records a route once and repeats it, replanning around obstacles; Orbit runs the fleet remotely |
|---|
| Environment |
|---|
| Ingress protection | Not rated by Unitree (IP54 quoted by some resellers) | IP66 | IP67 | IP54 |
|---|
| Operating temperature | 5 °C to 35 °C per Unitree's manual | −20 °C to 55 °C | −20 °C to 55 °C | −20 °C to 55 °C |
|---|
| Rain & dust | Dry, sheltered routes only | Heavy rain and dust | Heavy rain, dust, and brief immersion | Dust and splashing water; not sustained rain |
|---|
| Connectivity |
|---|
| Connectivity | Wi-Fi 6, Bluetooth 5.2, 4G + GPS | 72 V power input, Gigabit Ethernet, RF image transmission, OTA upgrades | Ethernet and 72 V payload power; Pro adds Wi-Fi, USB 2.0/3.0, and 5 / 12 / 24 V outputs | Wi-Fi 2.4 / 5 GHz b/g/n and Ethernet |
|---|
| Deployment fit |
|---|
| Best for | - Indoor floors, covered yards, and dry loading docks
- Short loops with frequent docking
- Proof-of-concept pilots and budget-led first deployments
| - Long paved perimeters, logistics yards, and campuses
- Sites that mix ramps, stairs, and open ground
- Patrols that need distance per charge
| - Substations, plants, tunnels, and outdoor perimeters
- Night and low-light routes with a thermal payload
- 24/7 fleets that dock and recharge without a hand on them
| - Indoor and sheltered industrial inspection rounds
- Thermal and gauge reading on a fixed, repeatable route
- Sites that want the robot docking and running itself between missions
|
|---|